
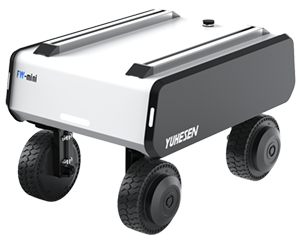
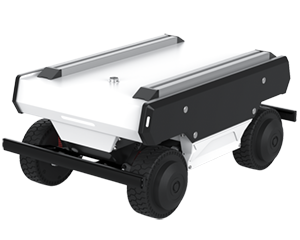
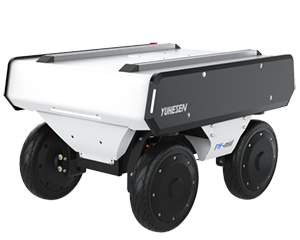
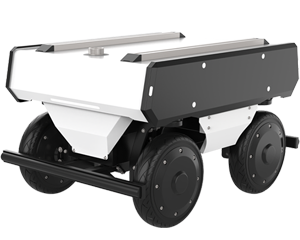
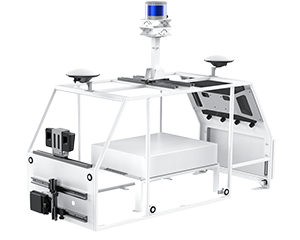

Omnidirectional 4WD-4WS vs 4WD Skid-Steer Chassis: An In-Depth Technical Comparison and Selection Guide for Mobile Robot Chassis
全向四驱四轮转向底盘与四驱滑移转向底盘:移动机器人底盘的深入技术比较和选型指南
在自主移动机器人(AMR)、工业检测车辆和特种作业车辆的研发过程中,移动机器人底盘是承载动力系统、导航系统和上部有效载荷的核心硬件平台。技术架构的选择直接决定了车辆运动性能、定位精度和长期维护成本的上限。
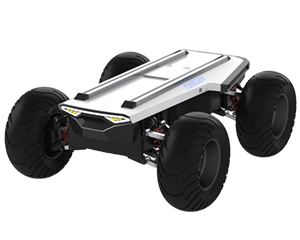
从技术角度来看,目前主流的四轮驱动移动底盘可分为两大类:
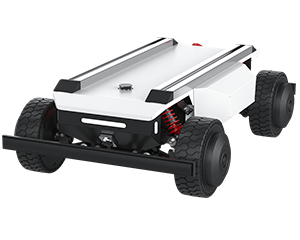
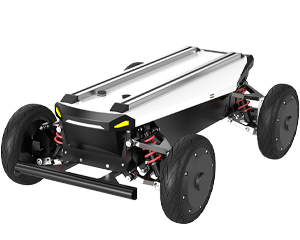
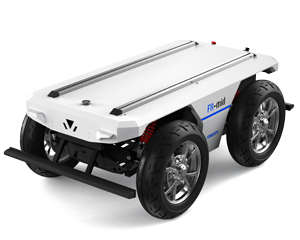
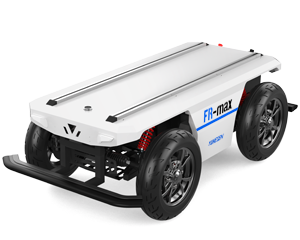
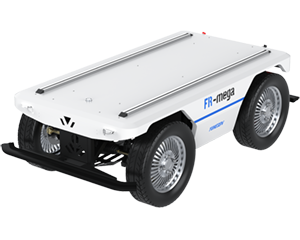
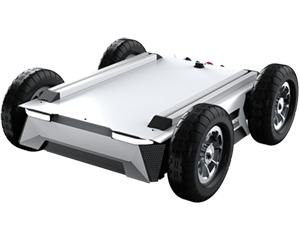
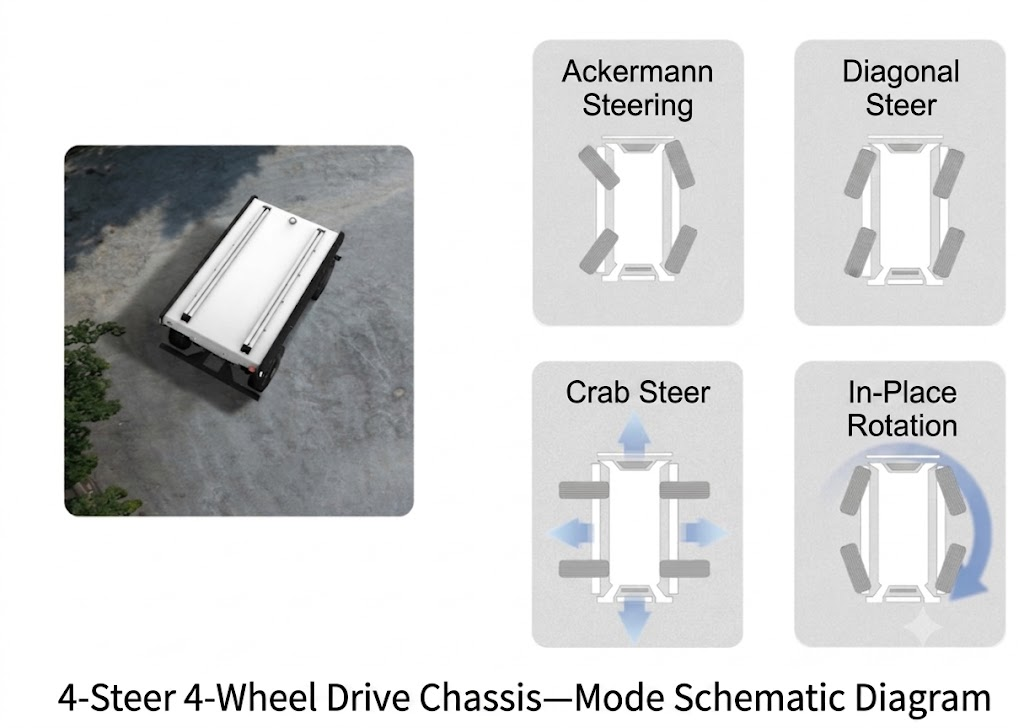
1)全向四轮驱动和四轮转向(4WD-4WS):采用分布式轮毂电机和独立的模块化线控转向单元;
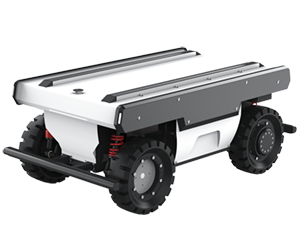
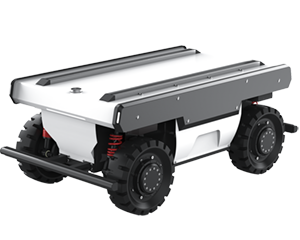
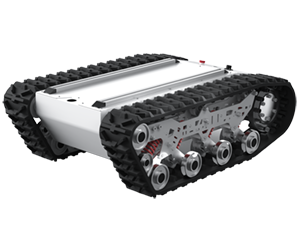
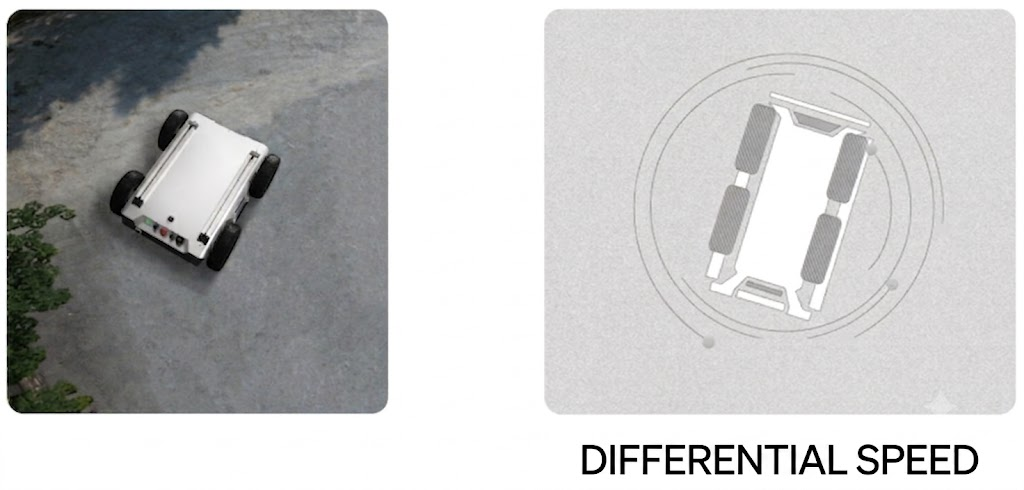
2)传统四轮滑移转向(4WD 滑移转向/差速驱动):通过左右车轮速度差产生的横向滑移实现转向。
在接下来的章节中,我们将从六个维度对两种解决方案之间的技术差异进行深入分析,并提出选择建议:技术原理、运动性能、运动模式、机械结构、维护成本和工业适应性。
| 比较维度 | 全方位四驱四轮驱动底盘 | 四轮驱动滑移转向底盘 |
|---|---|---|
| 转向与驱动原理 | 四个独立轮毂驱动装置 + 四个独立线控转向装置 | 通过左右电机实现差速驱动(滑移转向) |
| 地面摩擦与磨损 | 纯滚动摩擦;轮胎无额外横向剪切磨损 | 侧滑转向会导致严重的横向摩擦和轮胎严重磨损。 |
| 定位与控制精度 | 高(轨迹平滑,滑移最小;兼容激光雷达/视觉SLAM) | 易受地面摩擦力突变的影响;易发生位置漂移 |
| 机动性 | 支持传统的阿克曼转向、对角线行驶、横向(螃蟹)平移、原地旋转等。 | 仅支持直线行驶、大半径转弯和差速原地转向 |
| 机械传动系统 | Direct in-wheel drive; no gearboxes or complex transmission chains; high space utilization | Relies on gear reducers and chains/gearboxes; bulky structure with many maintenance points |
| Parking Safety | Supports "X"-shaped diagonal active self-locking parking; prevents rolling on slopes | Relies on mechanical brakes or static motor holding torque |
| Best-Fit Scenarios | High-precision indoor/outdoor inspection, loading/unloading in narrow aisles, R&D | Low-cost open outdoor sites, light-load transport, entry-level applications |
1. Technical Principles
1.1 Omnidirectional 4WD-4WS: Modular Steer-by-Wire Corner Modules
The omnidirectional 4WD-4WS chassis adopts an integrated architecture combining distributed in-wheel motors with steer-by-wire mechanisms. Each wheel is equipped with its own independent drive motor and steering actuator, completely eliminating the conventional mechanical steering column and linkage. Its core advantages are twofold:
1) Software-defined powertrain: the chassis control algorithm performs precise torque vectoring and coordinated steering-angle control across all four wheels.
2) High robustness: on bumpy surfaces or when a single wheel slips, the system can dynamically redistribute power to the remaining three wheels via the control algorithm, keeping the heading angle stable.
1.2 4WD Skid-Steer: Slip-Based Steering via Wheel-Speed Differential
A 4WD skid-steer chassis steers by controlling the speed difference between the left and right wheel sets (or even reversing one side). This approach has two inherent limitations:
1) Slip dependency: differential steering is essentially skid steering — during a turn, the tires are inevitably forced to slip against the ground in a non-circular direction.
2) Control uncertainty: steering resistance torque is highly dependent on the ground material (concrete, asphalt, epoxy flooring, wet tile, etc.). Encoder slip causes odometry errors to accumulate, increasing the fusion and matching difficulty for higher-level navigation algorithms such as LiDAR SLAM.
2. Motion Performance Comparison: Agility, Positioning Accuracy, and Traversability
2.1 Positioning Accuracy and Odometry Stability
When a 4WD-4WS chassis turns, its wheels remain predominantly in rolling contact, so wheel-speed sensor and encoder data more faithfully reflect changes in the vehicle's pose. Dead-reckoning errors accumulate slowly, making sensor fusion with high-precision navigation algorithms — such as LiDAR and visual SLAM — straightforward. By contrast, skid-steer turning depends on tire-to-ground slippage, and the actual slip ratio is strongly affected by the ground material (e.g., epoxy flooring, concrete, wet surfaces) and load distribution. This physical slip easily causes odometry drift, requiring more complex algorithmic compensation in applications that demand high repeat-positioning accuracy.
2.2 Terrain Adaptability and Tire Wear
Because lateral scrubbing during steering is minimized, a 4WD-4WS chassis experiences less tire wear when turning frequently on hard surfaces. Combined with a modular, low-mounted battery layout that lowers the vehicle's center of gravity, it delivers good driving stability on grass, gravel, and indoor-outdoor transition surfaces. A skid-steer chassis faces low steering resistance and performs well on soft terrain such as dirt and gravel; however, frequent turning on high-friction hard surfaces (such as epoxy floors in industrial workshops) accelerates tire wear and may leave scuff marks on the ground.
3. Motion Mode Analysis: Single Steering Mode vs. All-Scenario Multi-Mode Coverage
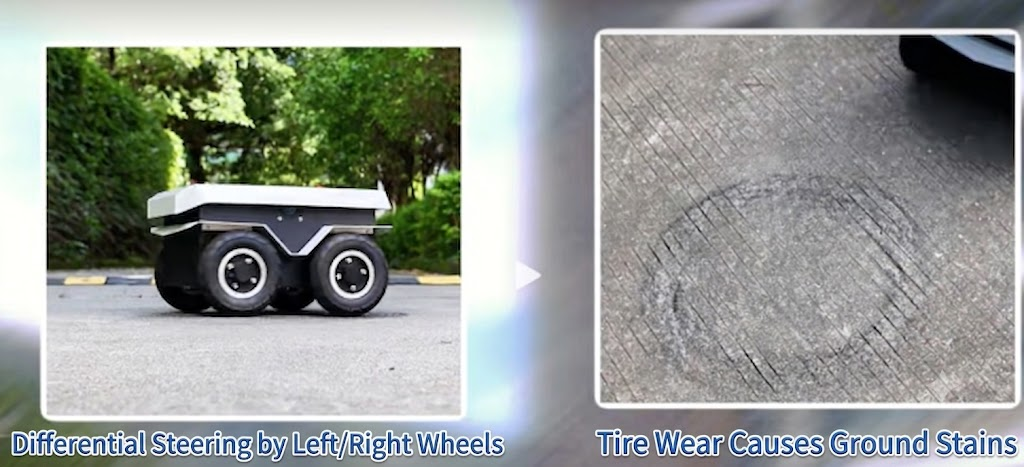
Reference example: floor wear caused by skid steering
When operating in confined spaces (such as equipment-dense server rooms or narrow warehouse aisles), a conventional skid-steer chassis often has to repeatedly perform large-angle "back-and-forth reversing + in-place skid rotation" maneuvers. This is not only inefficient but also easily scratches and wears epoxy flooring.
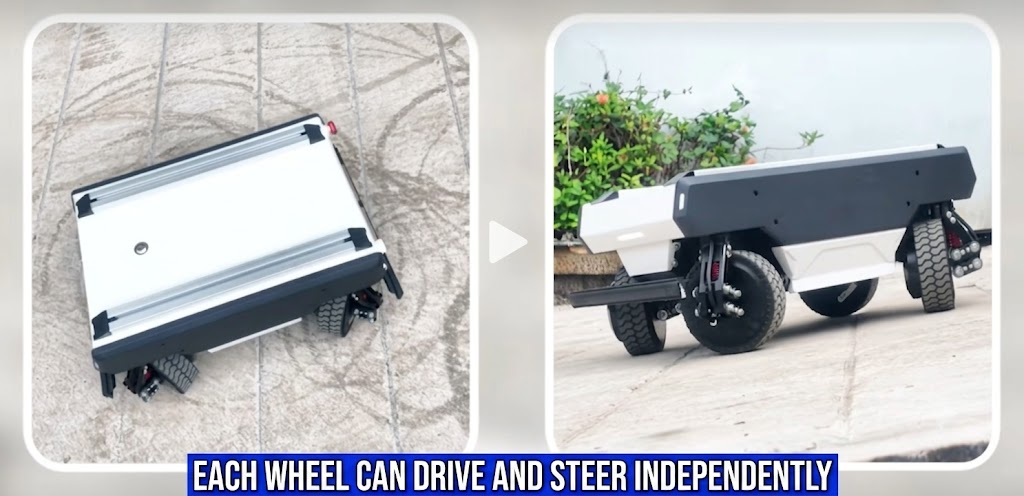
Reference example: independent four-wheel steering of a 4WD-4WS chassis
The YUHESEN omnidirectional 4WD-4WS chassis supports seamless switching between multiple motion modes, greatly expanding the operating envelope of special-purpose robots. These modes give the robot exceptional agility:
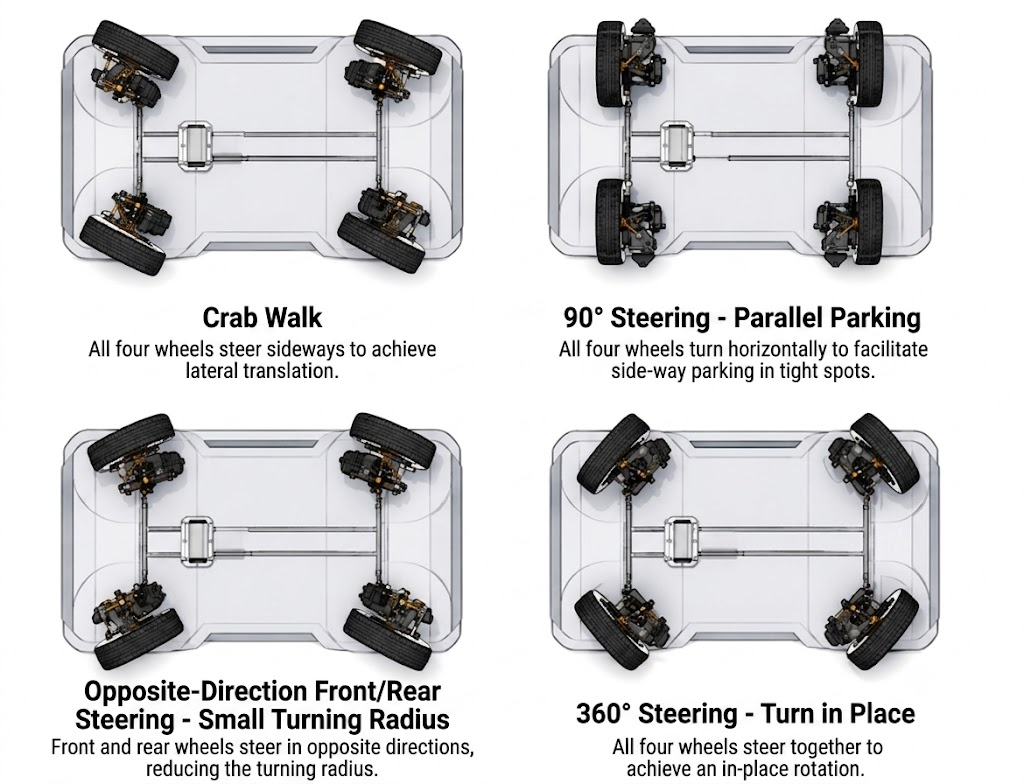
1) Dual-Ackermann Mode: the front and rear wheels steer in opposite directions, enabling a dynamically variable turning radius. During cornering, all wheels fully conform to the pure-rolling kinematic model, producing smooth trajectories while effectively reducing steering resistance and energy consumption.
2) Crab / Lateral Mode: all four wheels steer in the same direction, allowing the vehicle to translate purely sideways without changing its heading. Ideal for lateral docking in narrow aisles, charging alignment, and container side-loading operations.
3) Diagonal Mode: all four wheels steer in the same direction within a specific angular range, enabling fast diagonal lane changes while the body maintains its orientation. During high-speed lane changes, this effectively suppresses the yaw rate and eliminates lateral instability.
4) X-Parking Safety Design: all four wheels steer inward into an "X" configuration, mechanically interlocking with one another. Even in the event of power loss, shutdown, or operation on a slope, this creates a natural geometric self-locking resistance — delivering intrinsic safety with zero power consumption, no need for continuous motor energization, and absolutely no rolling on grades.
4. Mechanical Structure and Maintenance Cost Comparison
4.1 Component Count and Space Utilization
A 4WD skid-steer chassis typically requires gear reducers, chains, or gear transmission sets — a mature mechanical architecture. However, in compact robot designs, these transmission components occupy considerable assembly volume in the middle of the chassis.
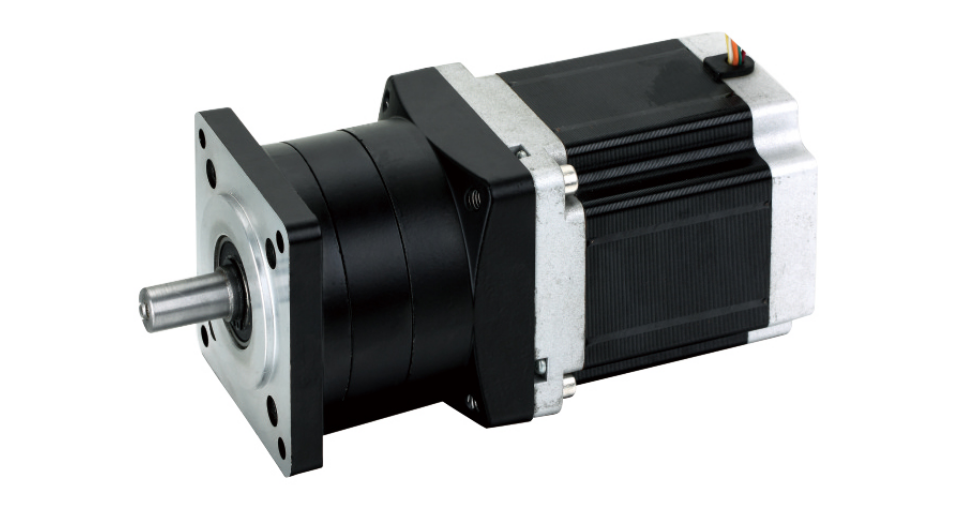
Example: motor configuration of a skid-steer chassis
The 4WD-4WS chassis uses direct in-wheel motor drive and integrated wheel-corner steering units, eliminating certain conventional intermediate transmission elements such as mechanical gearboxes, drive shafts, and differential linkages. This distributed structure significantly reduces internal mechanical occupancy, freeing up ample layout space for the power battery, industrial PC, lifting mechanisms, and various top-mounted sensors.
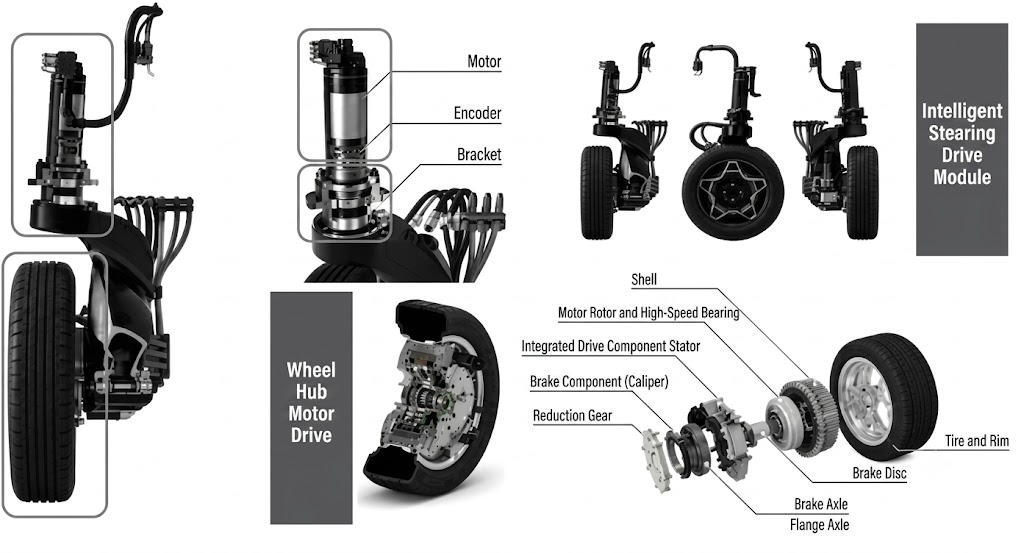
Example: motor configuration of a 4WD-4WS chassis
4.2 Mechanical Wear and Maintenance Intervals
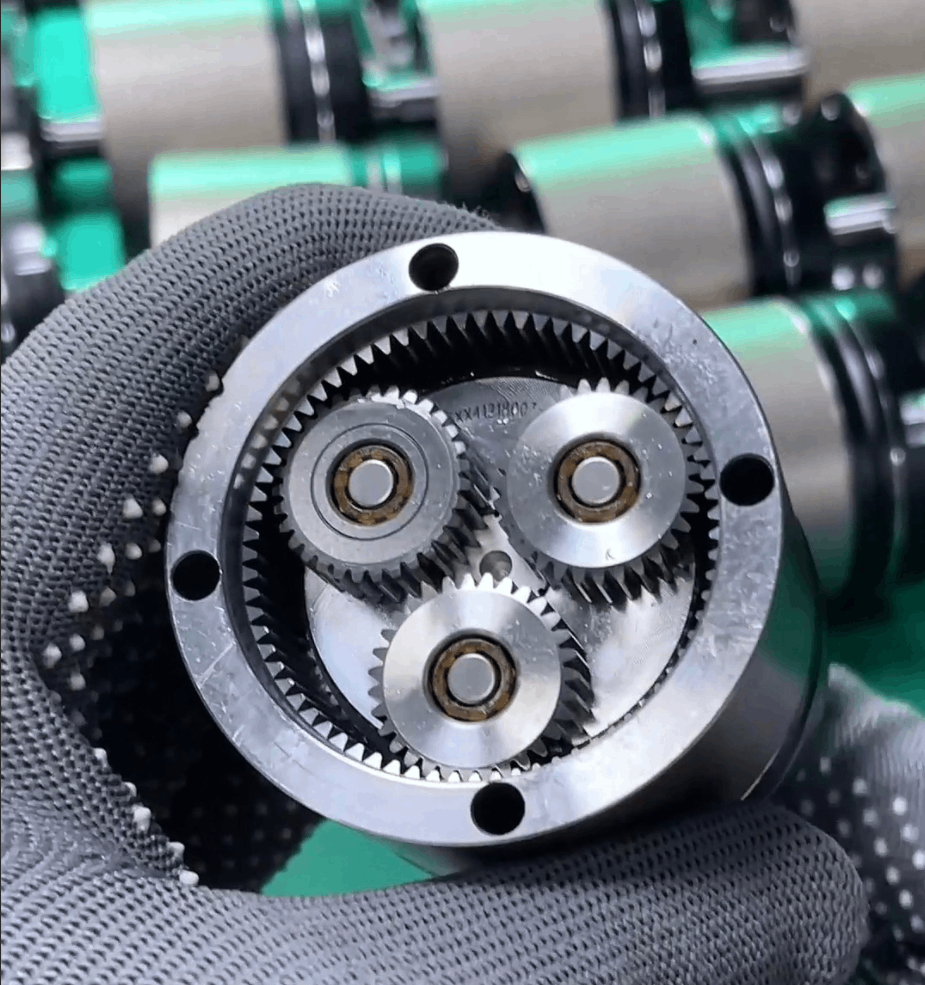
Example: reducer wear and maintenance case
When the mechanical transmission components of a skid-steer chassis endure steering shock loads and alternating stresses over extended periods, the gear backlash of the reducers, chain tension, and sealing condition all require regular inspection and maintenance. The 4WD-4WS chassis has relatively few intermediate transmission wear points; routine maintenance mainly involves standard checks of the electrical system and wheel-corner modules, with low maintenance demand related to mechanical clearances and transmission wear.
5. Scalability Comparison: Modular Design and Application Adaptability
In mobile robot R&D and feature expansion, the chassis's adaptability to different size specifications and payload requirements is likewise an important evaluation criterion:
The 4WD skid-steer chassis is a mature mechanical solution with high structural integration, making it well suited to mass-produced, standardized general-purpose mobility applications. However, because its powertrain and steering are tightly coupled, when the vehicle requires substantial track-width or wheelbase changes, or must carry complex superstructure functions, secondary expansion and structural flexibility are relatively limited.
In the omnidirectional 4WD-4WS chassis, every wheel is an independent drive-and-steering actuator unit. The chassis architecture offers greater decoupling and flexibility, allowing structural adjustments and functional derivatives to be implemented more readily according to different operating conditions, load ratings, and body-space requirements.
The YUHESEN omnidirectional 4WD-4WS mobile chassis adopts a modular wheel-corner system design, with drive and steering modules laid out independently. It supports flexible adjustment of chassis dimensions and payload configurations based on actual application needs, providing a more adaptable foundation for mobile robot development and solution integration.
6. Selection Conclusions and Recommendations
何时选择四驱滑移装载机底盘:预算极其敏感的项目;在平坦、柔软的地面(例如,松软的土壤、草地)上作业;对停车定位精度要求不高的入门级基本移动平台。
何时选择全向 4WD-4WS 底盘:需要高运动精度的应用;狭窄的工作空间;必须消除轮胎打滑和磨损的硬质地面;以及需要长续航时间和免维护运行的中高端应用场景——例如工业检查、变电站监控、防爆特种作业和大学/研究二次开发平台。


